
Drone Lab
Drone Lab @NTNU in Ålesund
Drone Lab Ålesund is a research laboratory run by the research group Cyber-Physical Systems Laboratory (CPS Lab) at the Department of ICT and Natural Sciences, NTNU in Ålesund.
The lab supports the CPS Lab's research on robotics and autonomous systems, and is a hub for research, innovation and education in drone technology at the department. Each year, the lab hosts several BSc and MSc projects (see below for recent projects), and student projects in the course AIS2205 Autonomous Systems. Many BSc and MSc projects are carried out in collaboration with industry (Kongsberg Maritime, Griff Aviation and more) and used to support our PhD research projects on relevant topics.
.

Infrastructure
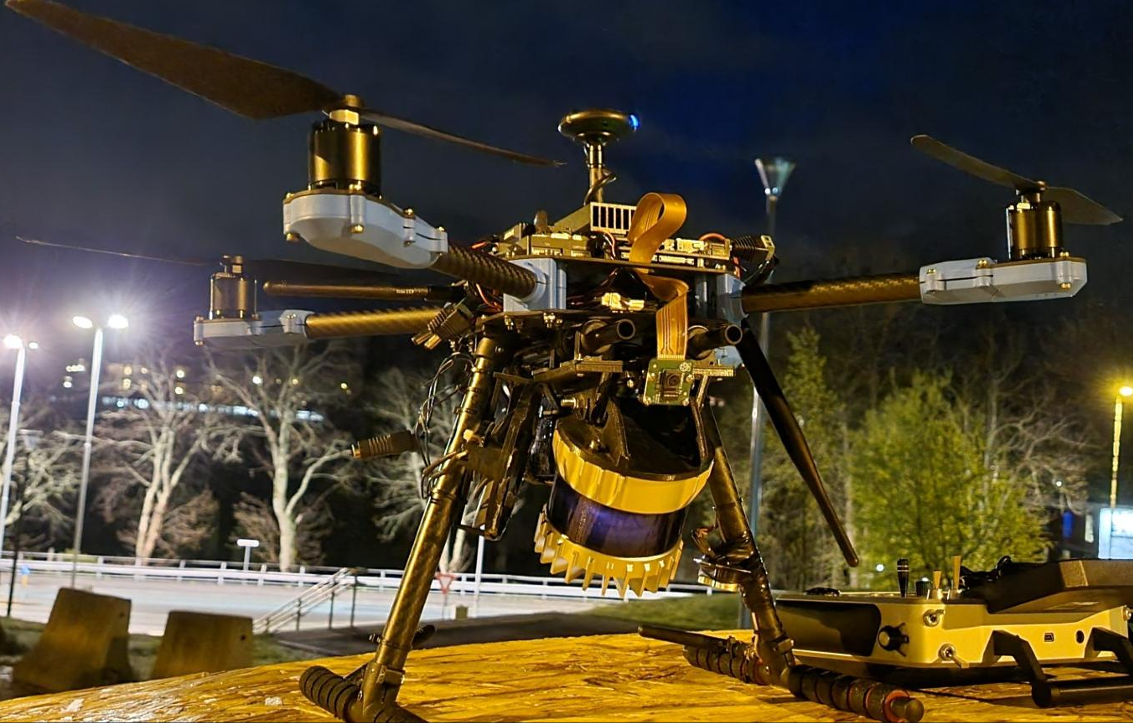
The lab has a range of aerial and marine robots, including:
Quadrotor UAVs
- 2 x Holybro X500 v2
- 2 x Hexsoon EDU-450 V2
- DJI Mavic Air 2
- 10 x Ryze Tello
Fixed-wing/VTOL UAVs
- H-King Bixler 3 Glider
- HeeWing T1 Ranger VTOL
- HeeWing T2 Cruza VTOL
- A custom made tilt-wing VTOL plane
USVs
- Maritime Robotics Otter USV
- Several custom made USVs
Underwater robots
- BlueROV2
We collaborate with Fjordlab Ålesund, which has access to additional USVs and UAVs, both commercial and custom drones.
Simulation software
threepp is an open-source C++ and Python library for 3D simulation and visualisation, developed at NTNU in Ålesund. We use it to build digital twins of the environments our drones and surface vessels operate in, with simulated cameras, lidar and other sensors, so that perception and control can be tested on the desk before going live. The image shows a twin of Nørvasundet in Ålesund, built from public Norwegian map data and rendered in threepp.

Current PhD Projects
- Sanjeev Kumar Ramkumar Sudha - Informative trajectory planning for environmental monitoring with autonomous surface vessels (Sweet Spot)
- Joel Jose - Explainability and human interaction in maritime collision avoidance systems (SFI AutoShip)
- Kai Erik Hoff - Acoustic perception for autonomous systems
Recent BSc/MSc projects
- Grey-Box Data-Driven System Identification of a Wind-Propelled USV Using WyNDA
- Autonomous Drone-Based Water Sampling and In-Situ Quality Monitoring for Hazardous and Inaccessible Aquatic Environments
- Design, Construction, and System Integration of the USV Selene
- Prototype Development of a Tilt-Wing VTOL UAV
- Multi-domain drone swarm communication - Norwegian Research Information Repository
- Kongsberg Maritime USV - USV integrated with Kongsberg Maritime M50/M100 systems
- Acoustic-Visual Drone Detection
- Text-Based Target Tracking for Autonomous Drones – Combining RGB Cameras, Event Cameras, and Vision-Language Models
- Autonom landing av drone på bevegelig plattform
- Investigating the Use of Polarized Cameras for Improved Visibility in a Maritime Environment
- Autonom vaskerobot til flytende solcellesystem
- Distributed 3D-SLAM for Small Autonomous Agents
- Toward Cleaner Oceans: Developing an ROV-Based Solution for Subsea Fishing Trash Collection
- Sparse Identification of Nonlinear Dynamics in Digital Twins for an Unmanned Surface Vessel
- UGV Dead-reckoning in GNSS Denied Environments
- Utdannings- og testdrone for Griff Aviation
- Design og produksjon av autonom drone
- Objektdeteksjon med YOLOv8 og LiDAR for maritim sikkerhet
- Autonomous Drone Props in Theatre
- Deep Reinforcement Learning for Interpretable Autonomous Navigation of Surface Vessels
